
October 8, 2026
news, seminar
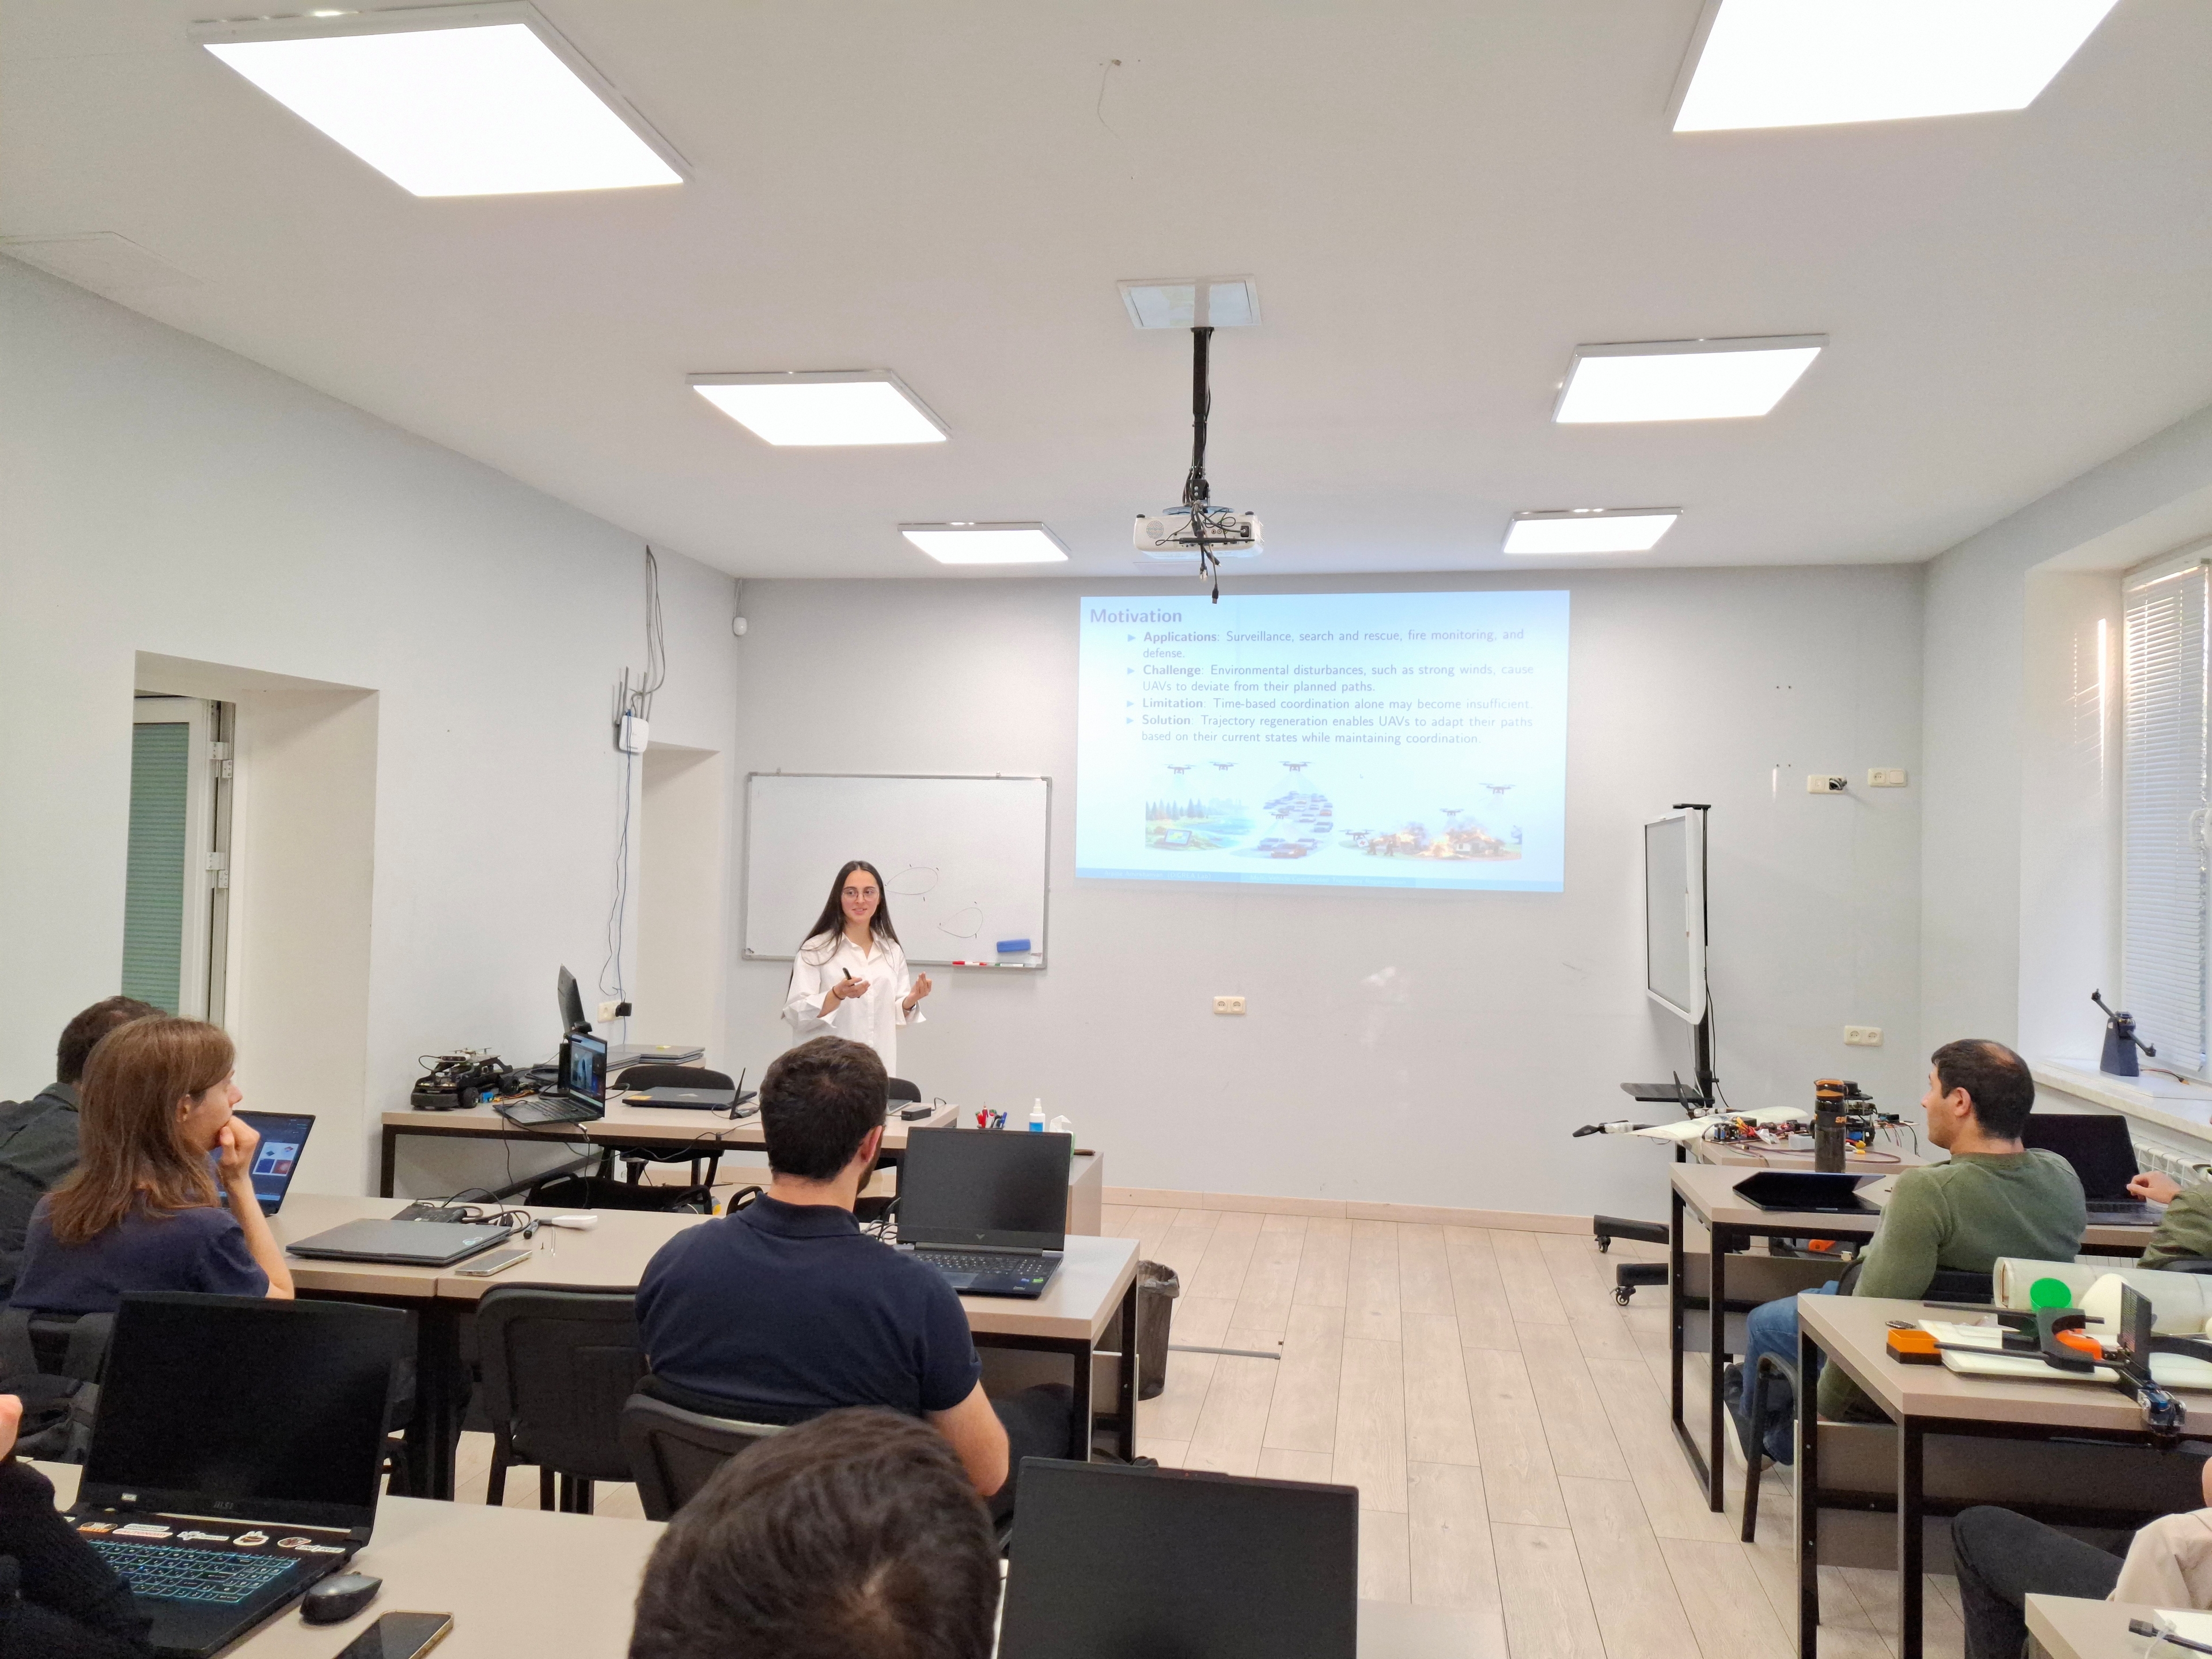
Seminar on Multi-Vehicle Coordinated Trajectory Regeneration
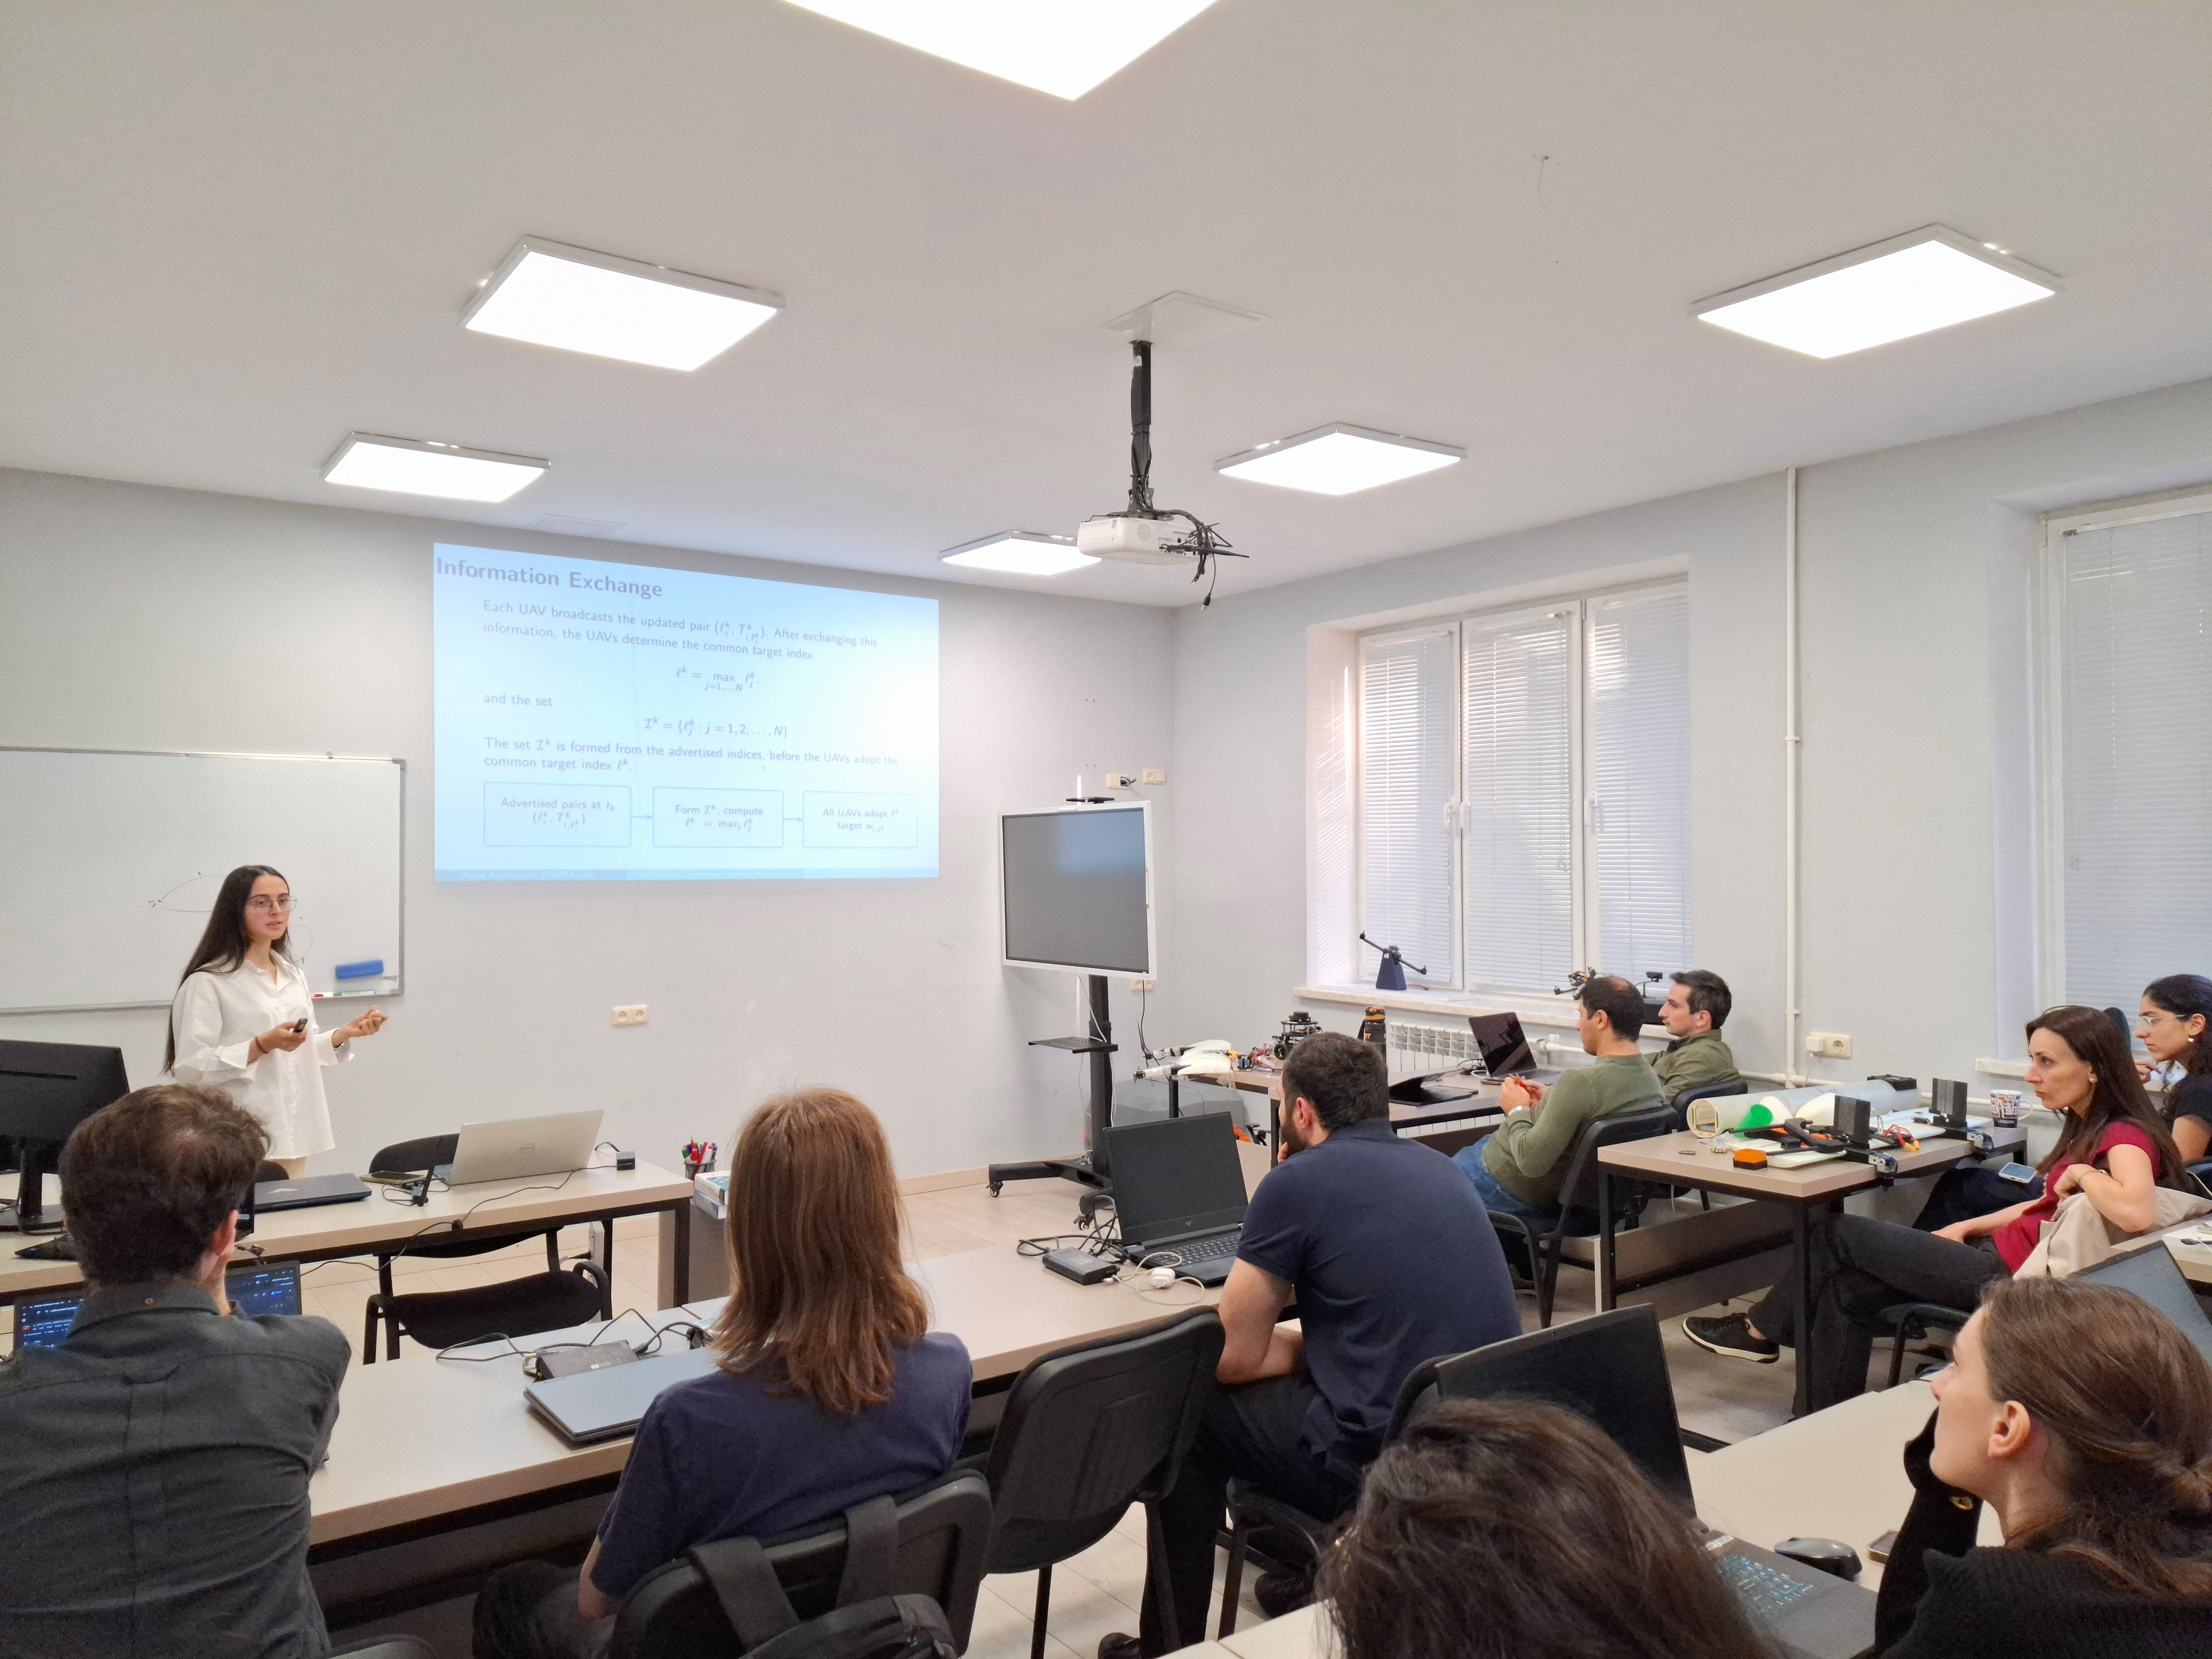
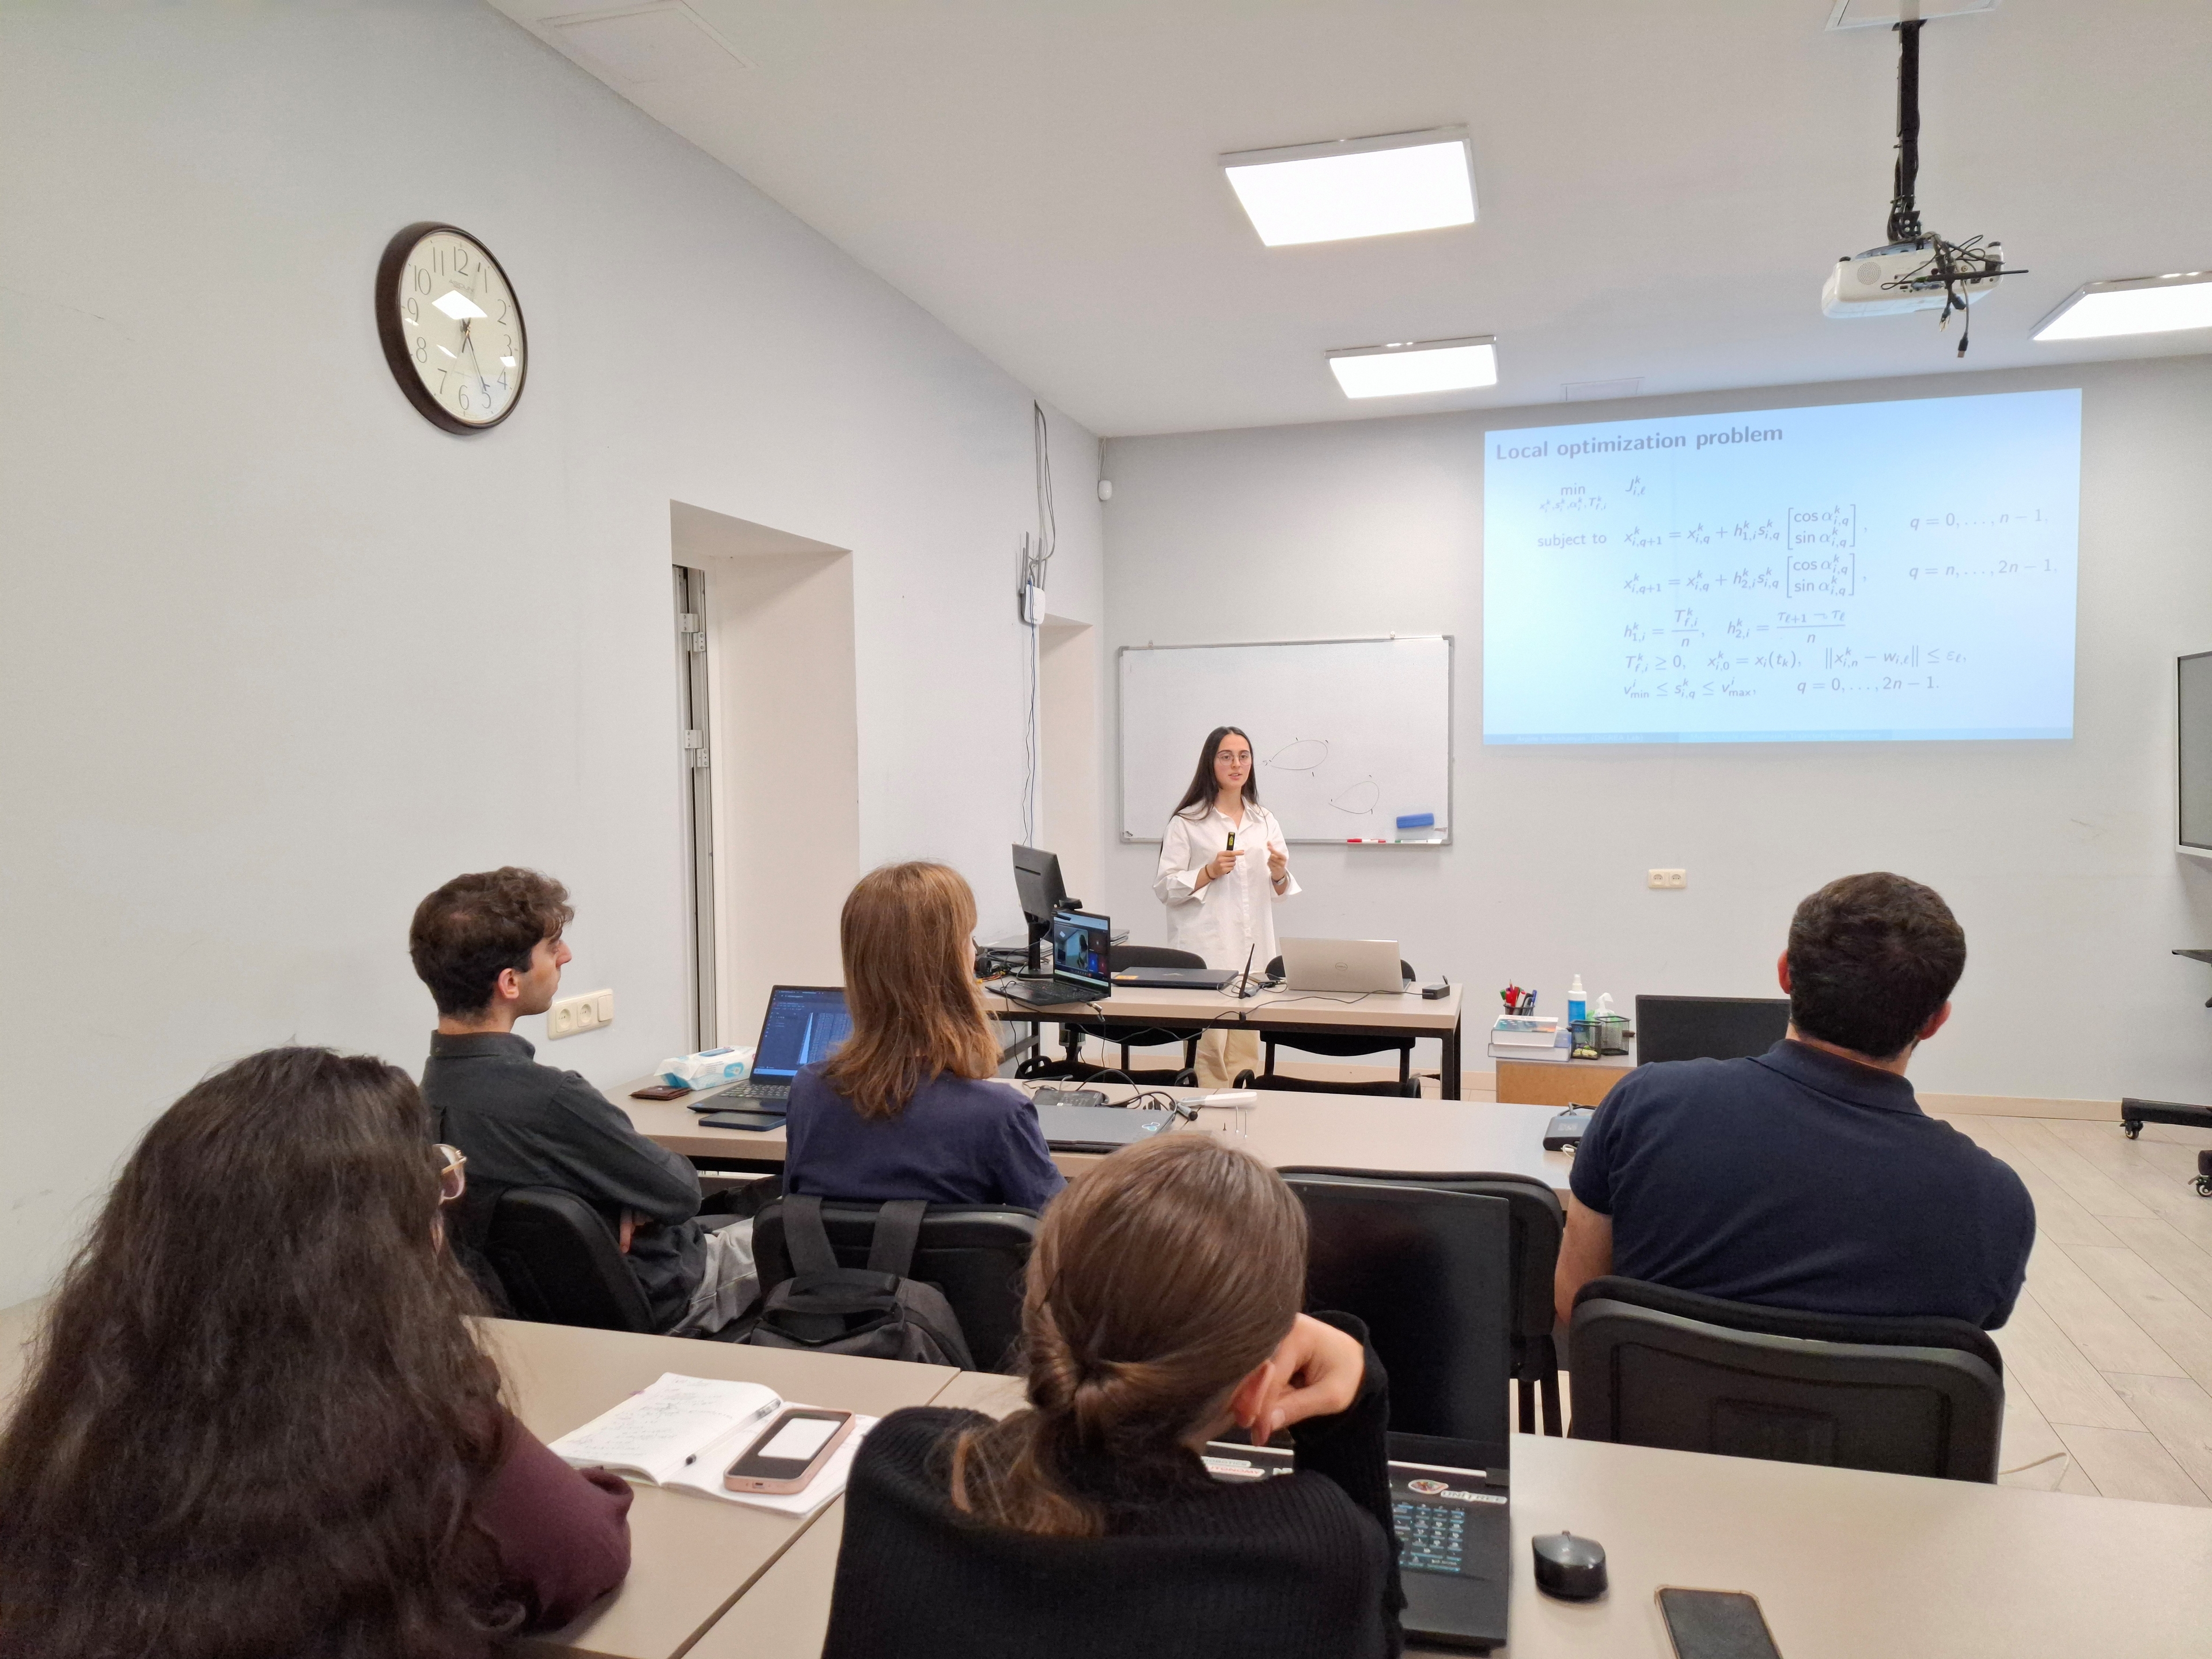
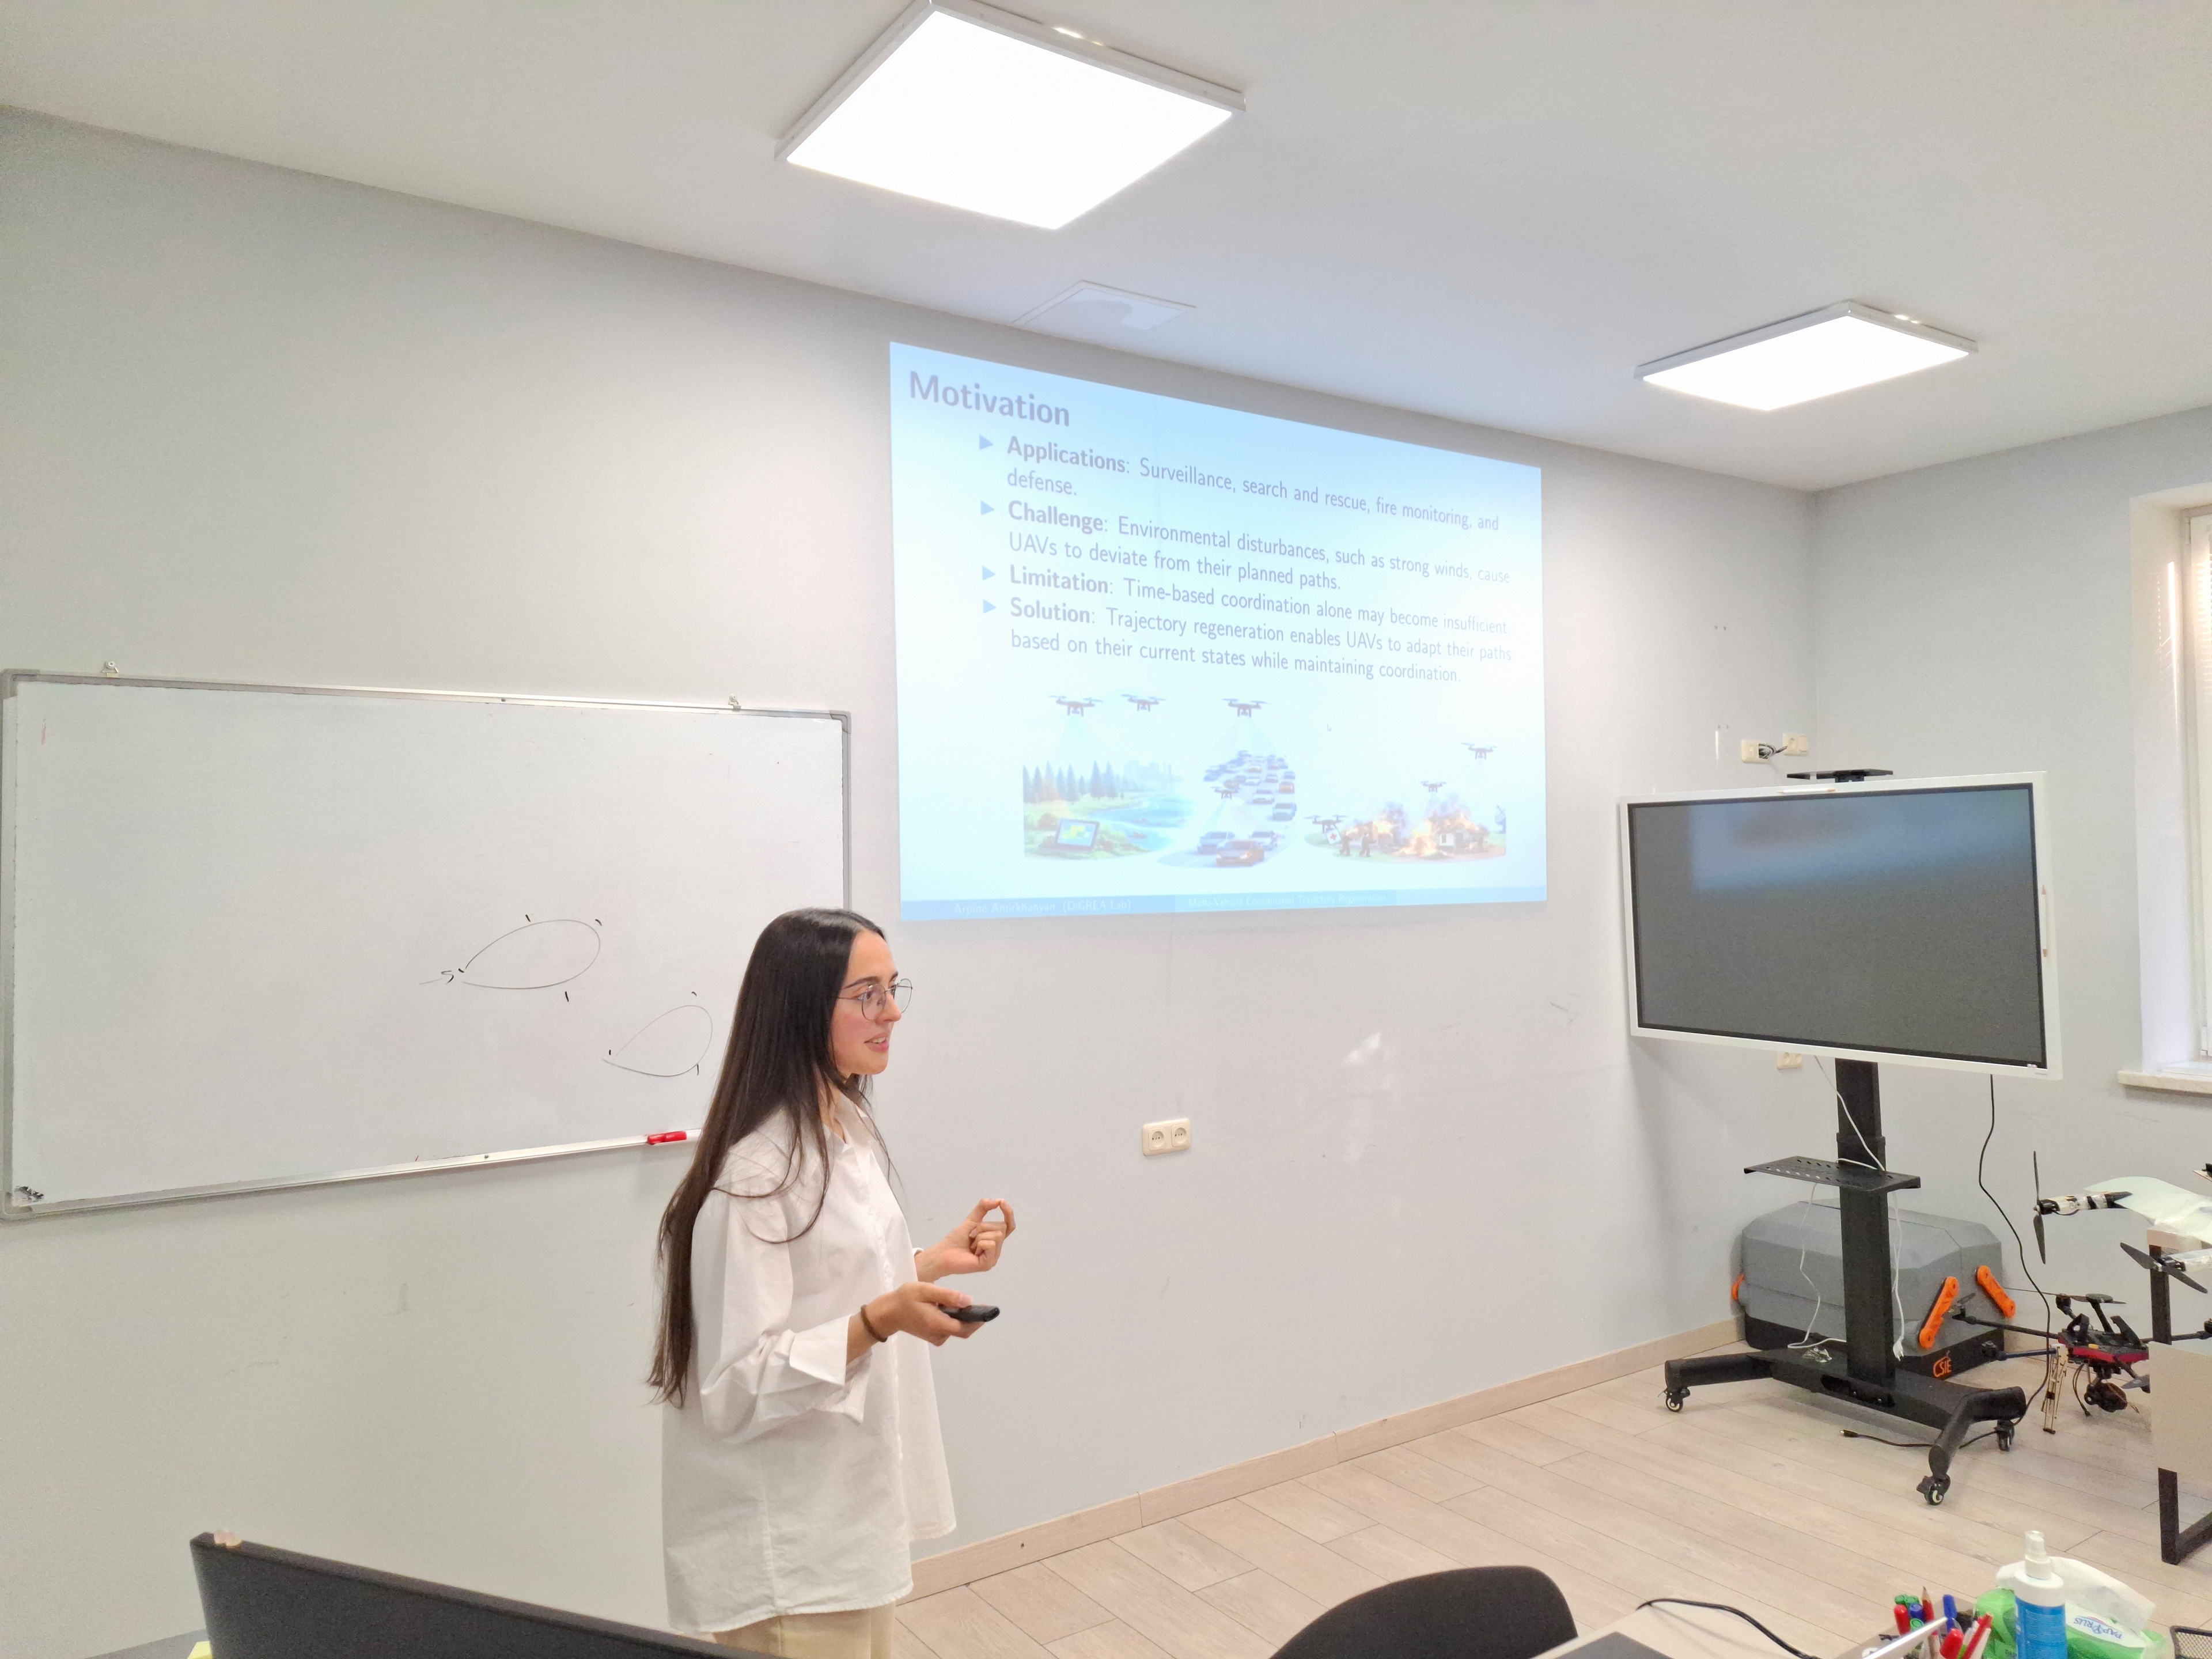
On October 8 at 17:00, the 16th seminar of the CSIE Seminar Series explored coordinated trajectory planning for multiple unmanned aerial vehicles (UAVs).
The seminar was delivered by CSIE/DiGREA Lab junior researcher Arpine Amirkhanyan. The research was conducted in collaboration with Tigran Bakaryan, Lusine Poghosyan, researchers at the DiGREA Lab, CSIE, and Michael Poghosyan.
Participants learned how UAVs can adapt their trajectories to environmental disturbances while maintaining coordination. The presented approach uses distributed optimization and information exchange between UAVs to regenerate trajectories based on their current positions and synchronize their arrival times. Simulation results demonstrated the effectiveness of the proposed method in coordinated multi-UAV navigation.
Are you interested in what we do?
Become our team member!
LEARN MORE